Research
My research aims to build next-generation intelligent control systems that learn and adapt from real-world interactions while preserving closed-loop stability, safety, robustness, and performance guarantees. My approach is to develop closed-loop adaptive reinforcement learning as a principled bridge between reinforcement learning, adaptive control, online optimization, and data-driven control.
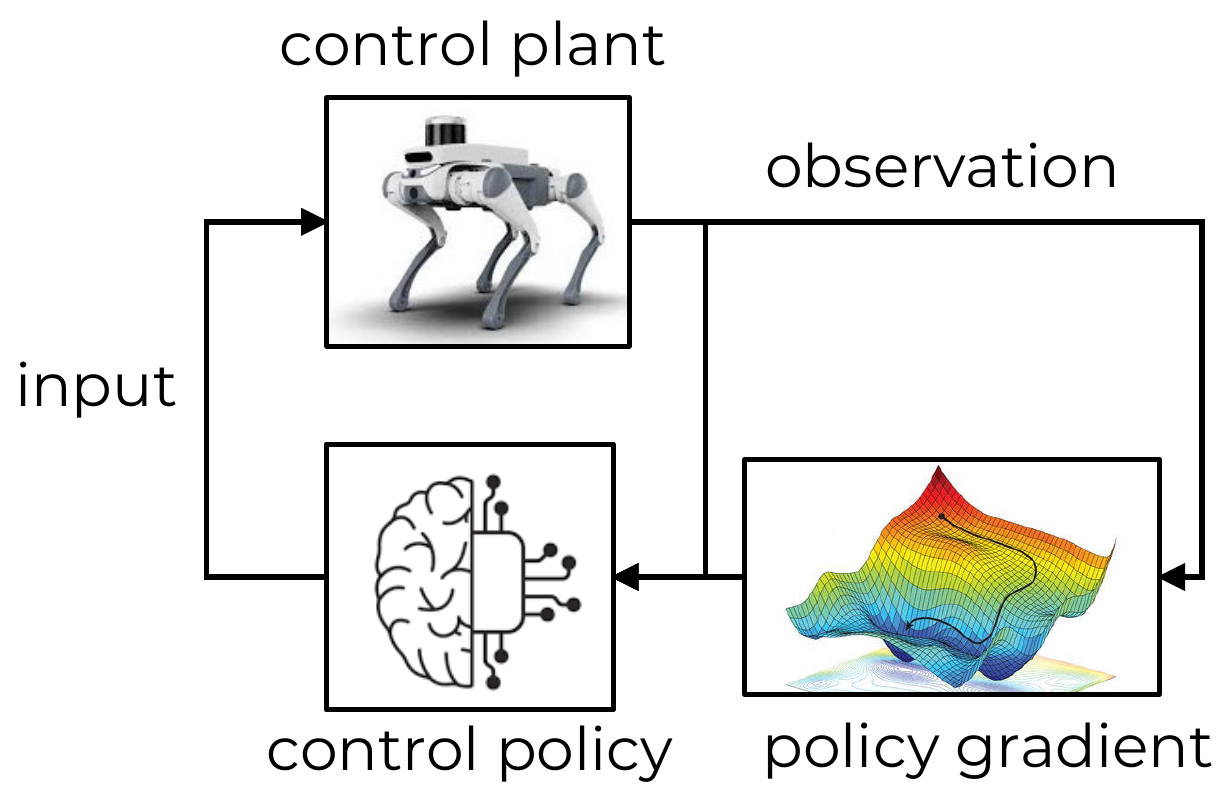
Closed-Loop Adaptive Reinforcement Learning
I develop policy-gradient and adaptive-learning methods that update controllers directly inside feedback loops while preserving stability, robustness, and performance guarantees for dynamical systems.
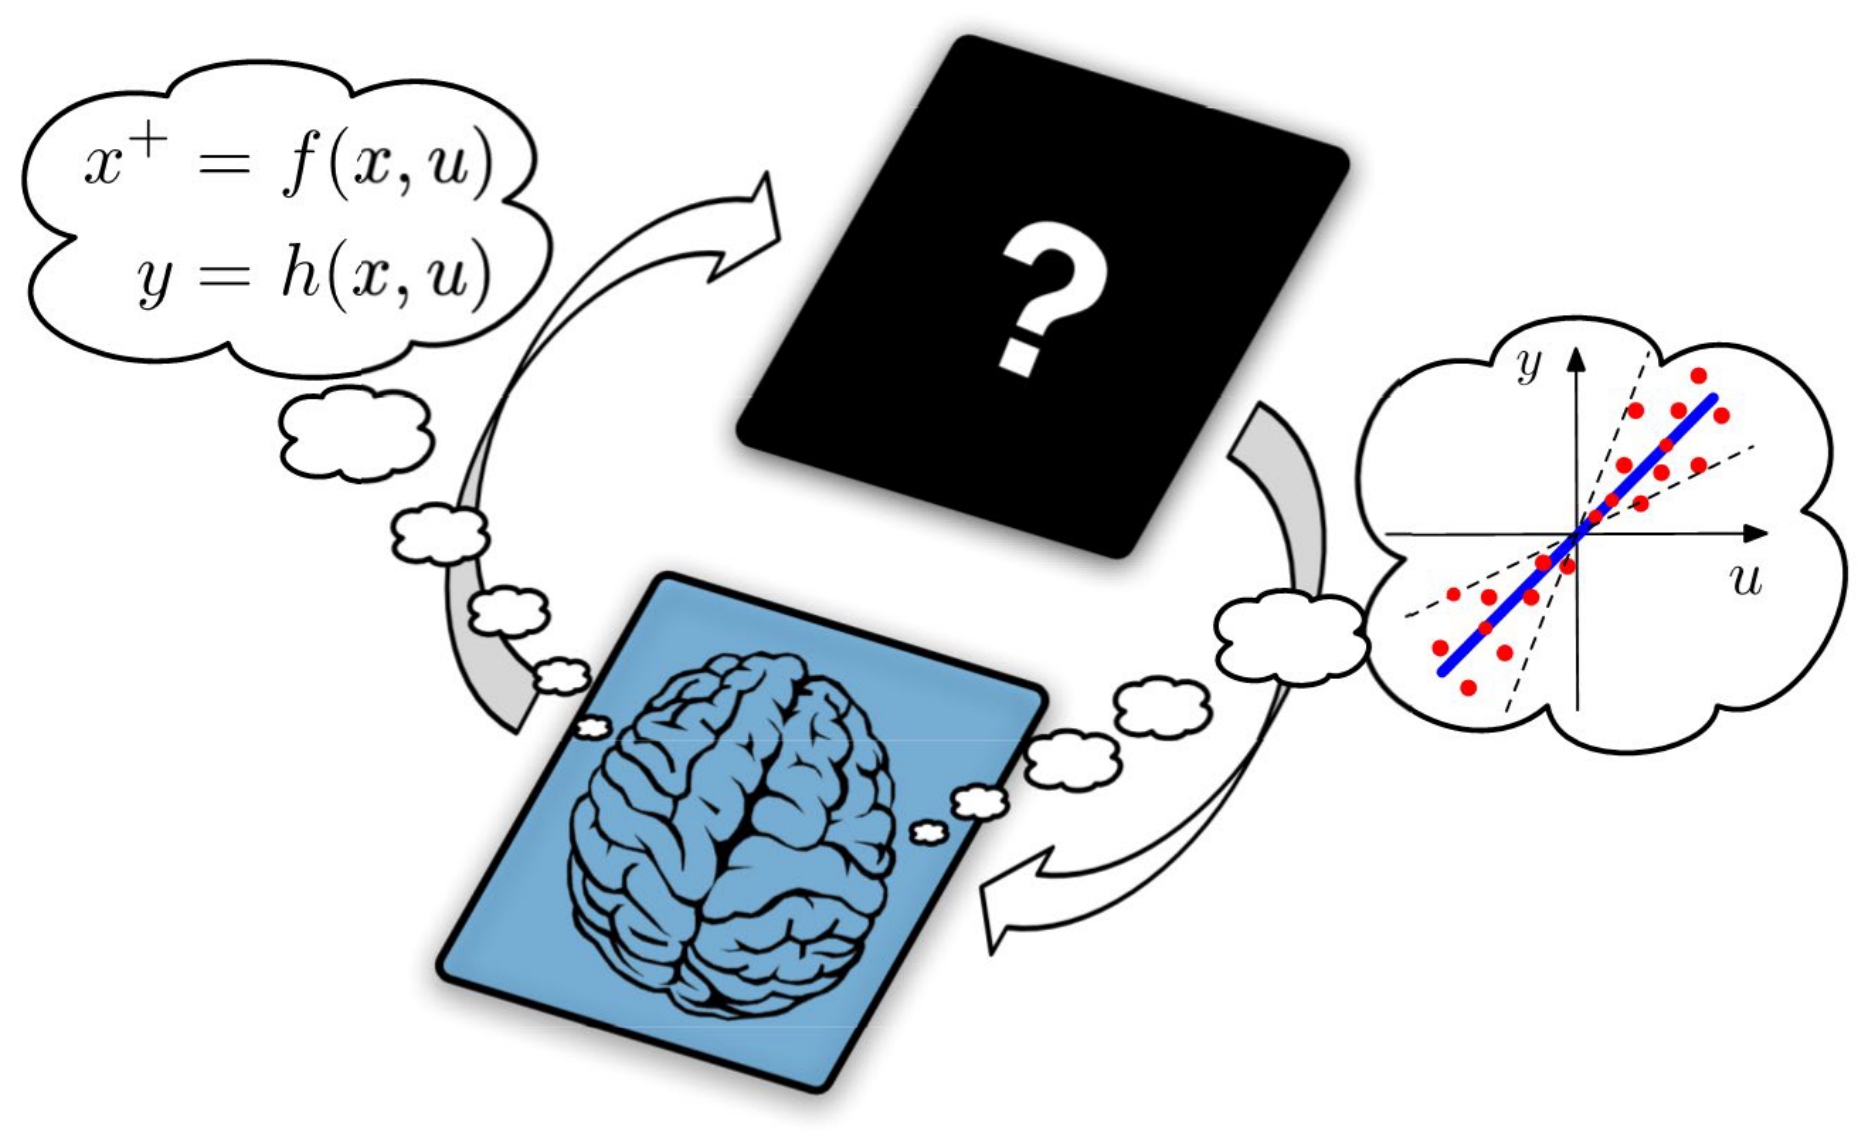
Data-Driven Control and Online Optimization
I study how finite data, behavioral representations, regularization, and online optimization can be turned into reliable controllers without first building a full parametric model.
Applications to Cyber-Physical Systems
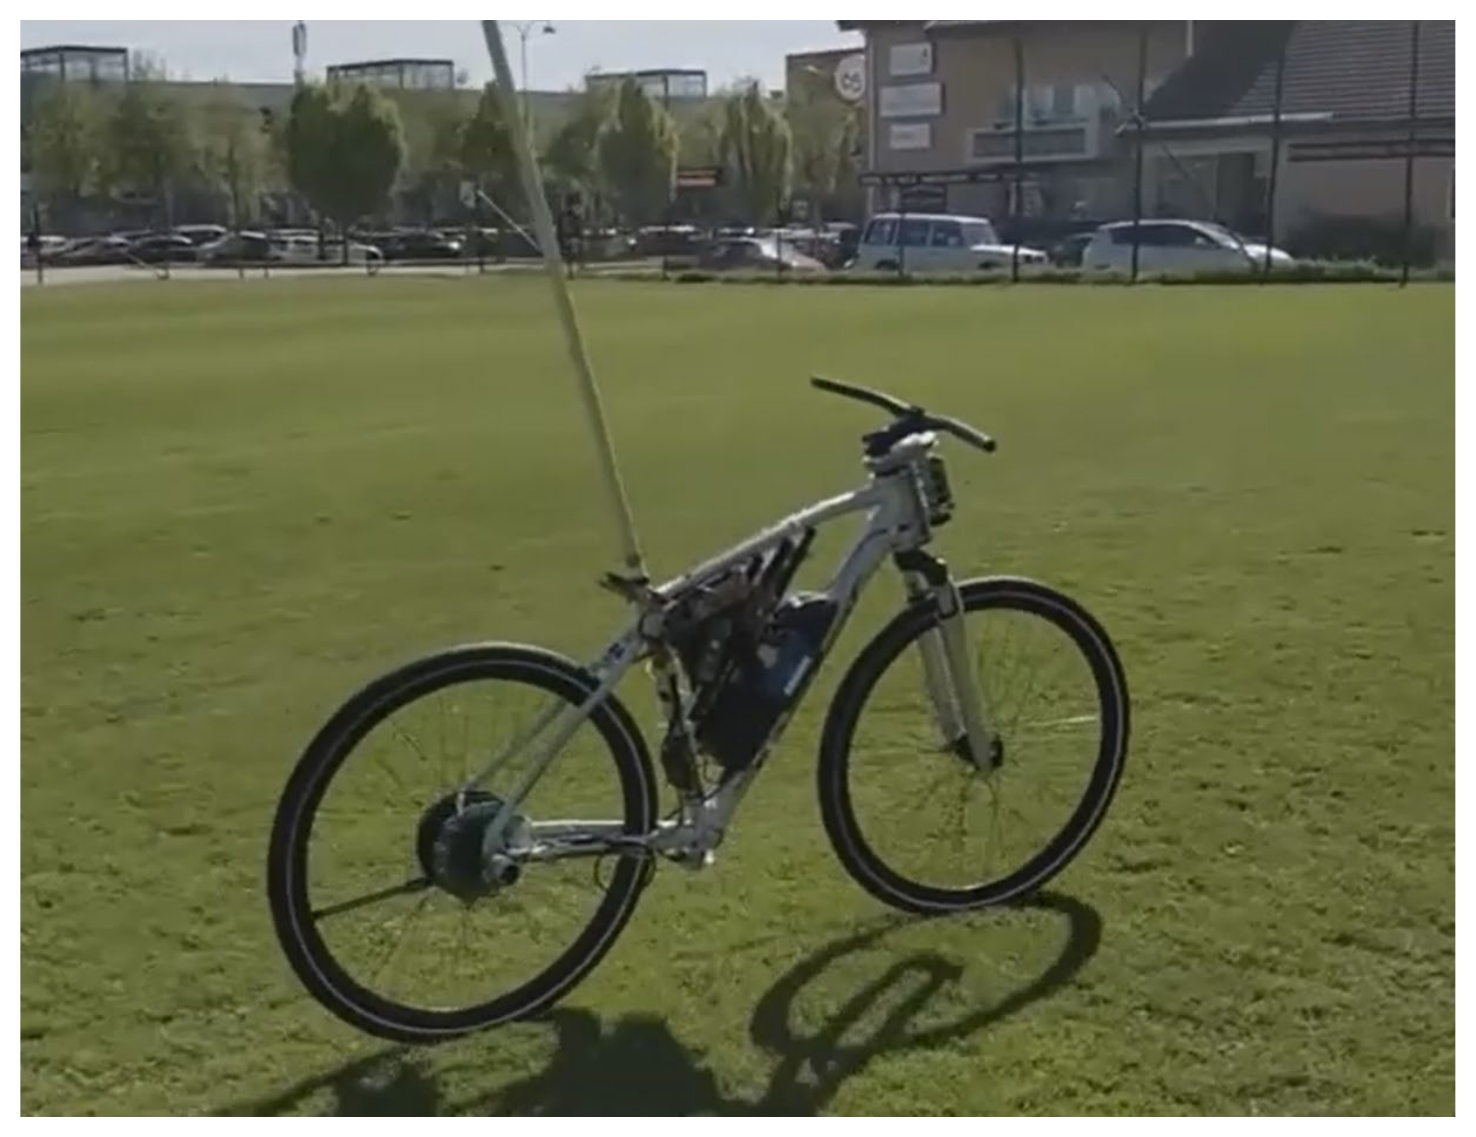
I translate learning and data-driven control ideas to embodied and safety-critical systems, including autonomous mobility, energy networks, power electronics, aerospace systems, and transportation.